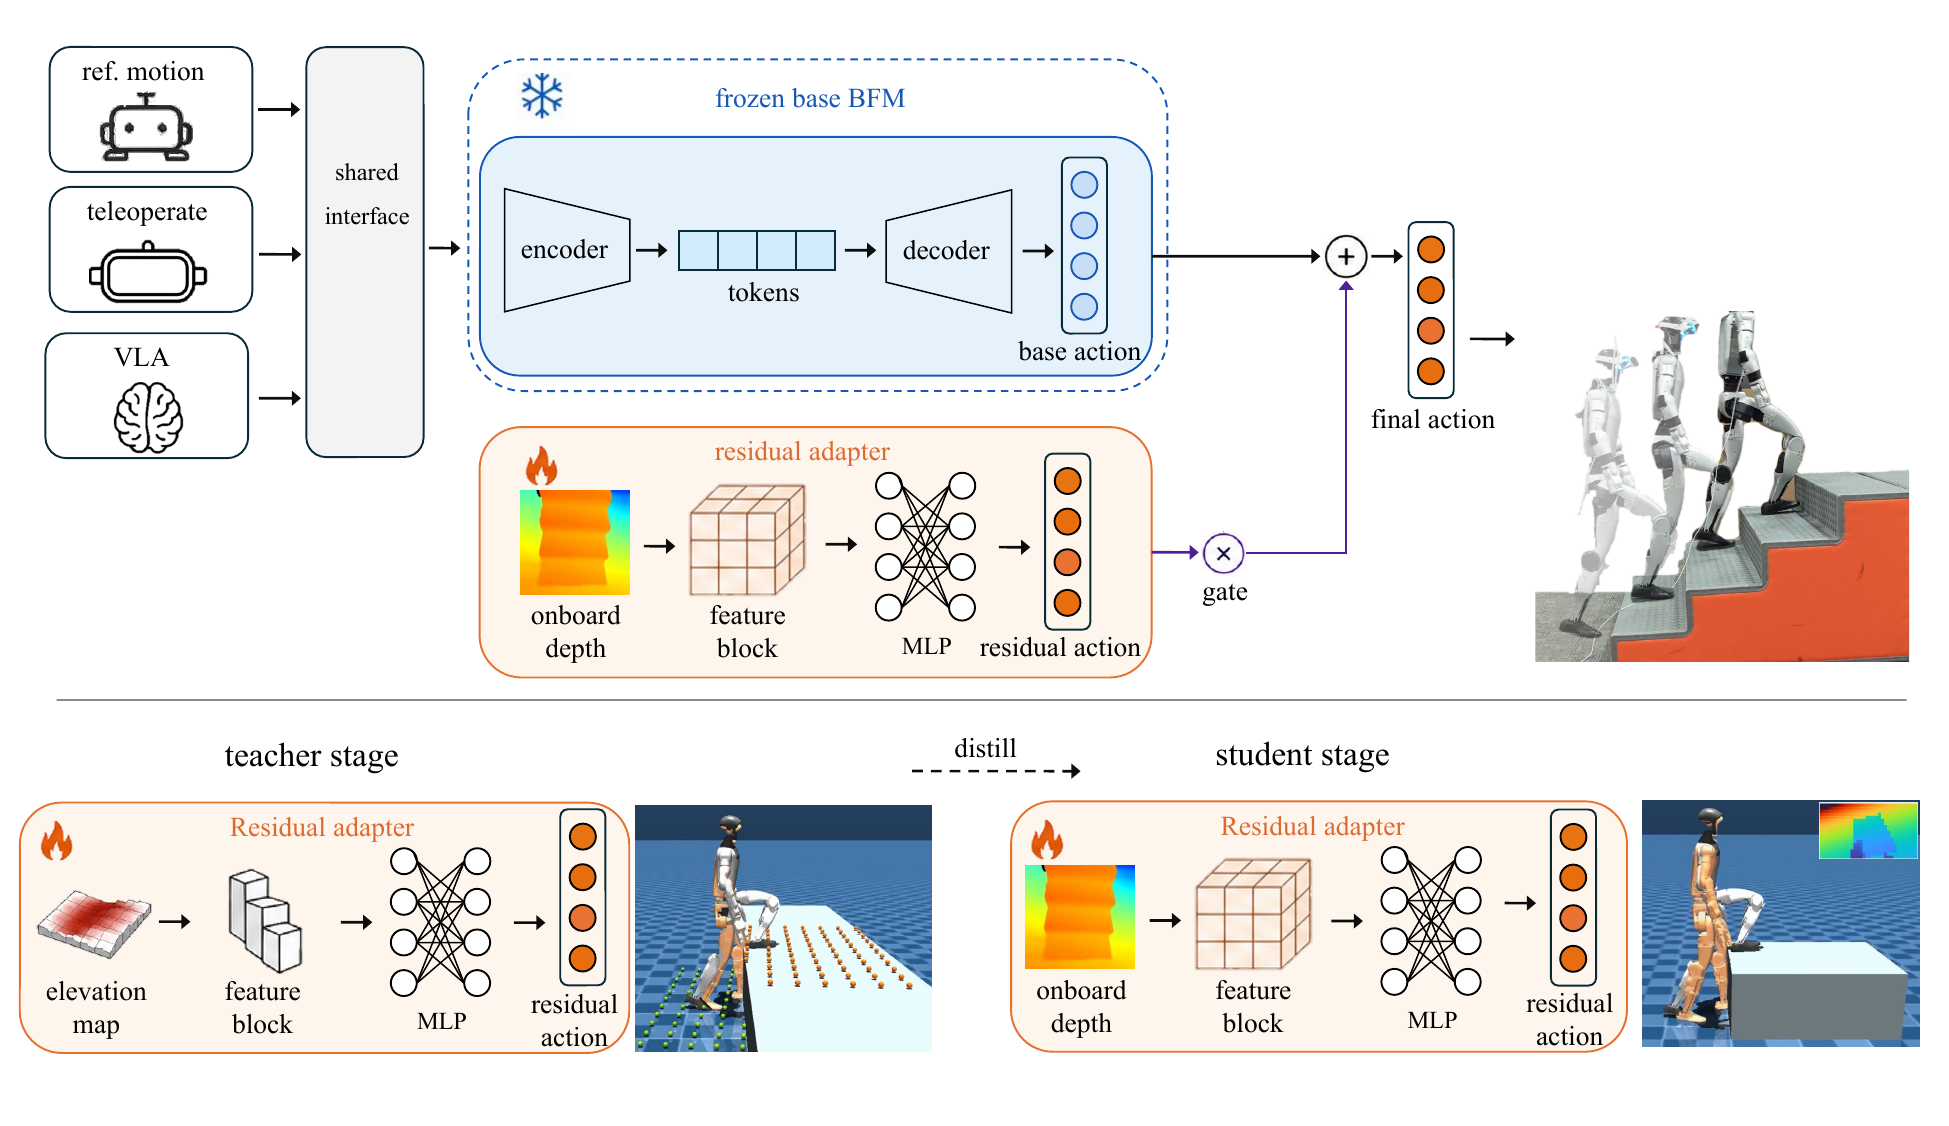
Humanoid behavior foundation models (BFMs) provide reusable whole-body motion priors: given a kinematic reference, they generate coordinated joint commands for motion replay, teleoperation, and VLA control. However, trained primarily on flat-ground motion, BFMs lack an explicit mechanism to adapt foot placement, swing clearance, and contact timing to local terrain. Many terrain-aware BFM approaches address this limitation by retraining or fine-tuning the tracker together with perception, incurring substantial data and computation costs while coupling ordinary tracking to the perception pathway. To bridge this gap, we propose GRAFT, a geometry-aware residual adaptation framework for frozen behavior trackers. GRAFT preserves the BFM parameters and motion-reference interface, while a lightweight adapter adds terrain-conditioned corrections only to lower-body execution targets. The adapter is trained with task and foot-geometry rewards, regularized to suppress unnecessary corrections on flat ground, and distilled from privileged terrain observations to onboard depth. Because the frozen BFM already provides whole-body reference tracking and nominal locomotion, GRAFT reduces terrain learning to a focused execution-adaptation problem. We instantiate the framework on four frozen trackers and evaluate stairs, gaps, and platforms in simulation. We further validate it through real-world deployment on a Unitree G1, where the adapted SONIC tracker traverses terrain with onboard depth and unmodified references.